
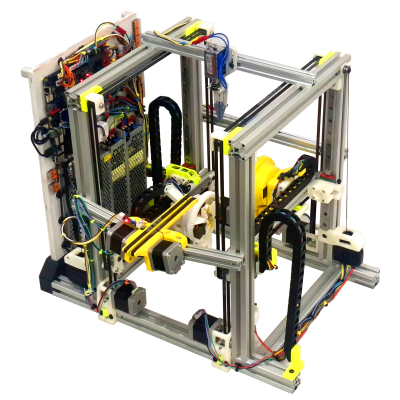
[Jude Robinson]’s robot Daisy has an unusual function: making a literal chain of daisies. The device is his student final project and demonstrates how a system can replace sensing with clever mechanical constraints. Instead of bringing tools to bear on each daisy, the daisies are brought to the tools in a repeatable, deterministic way.
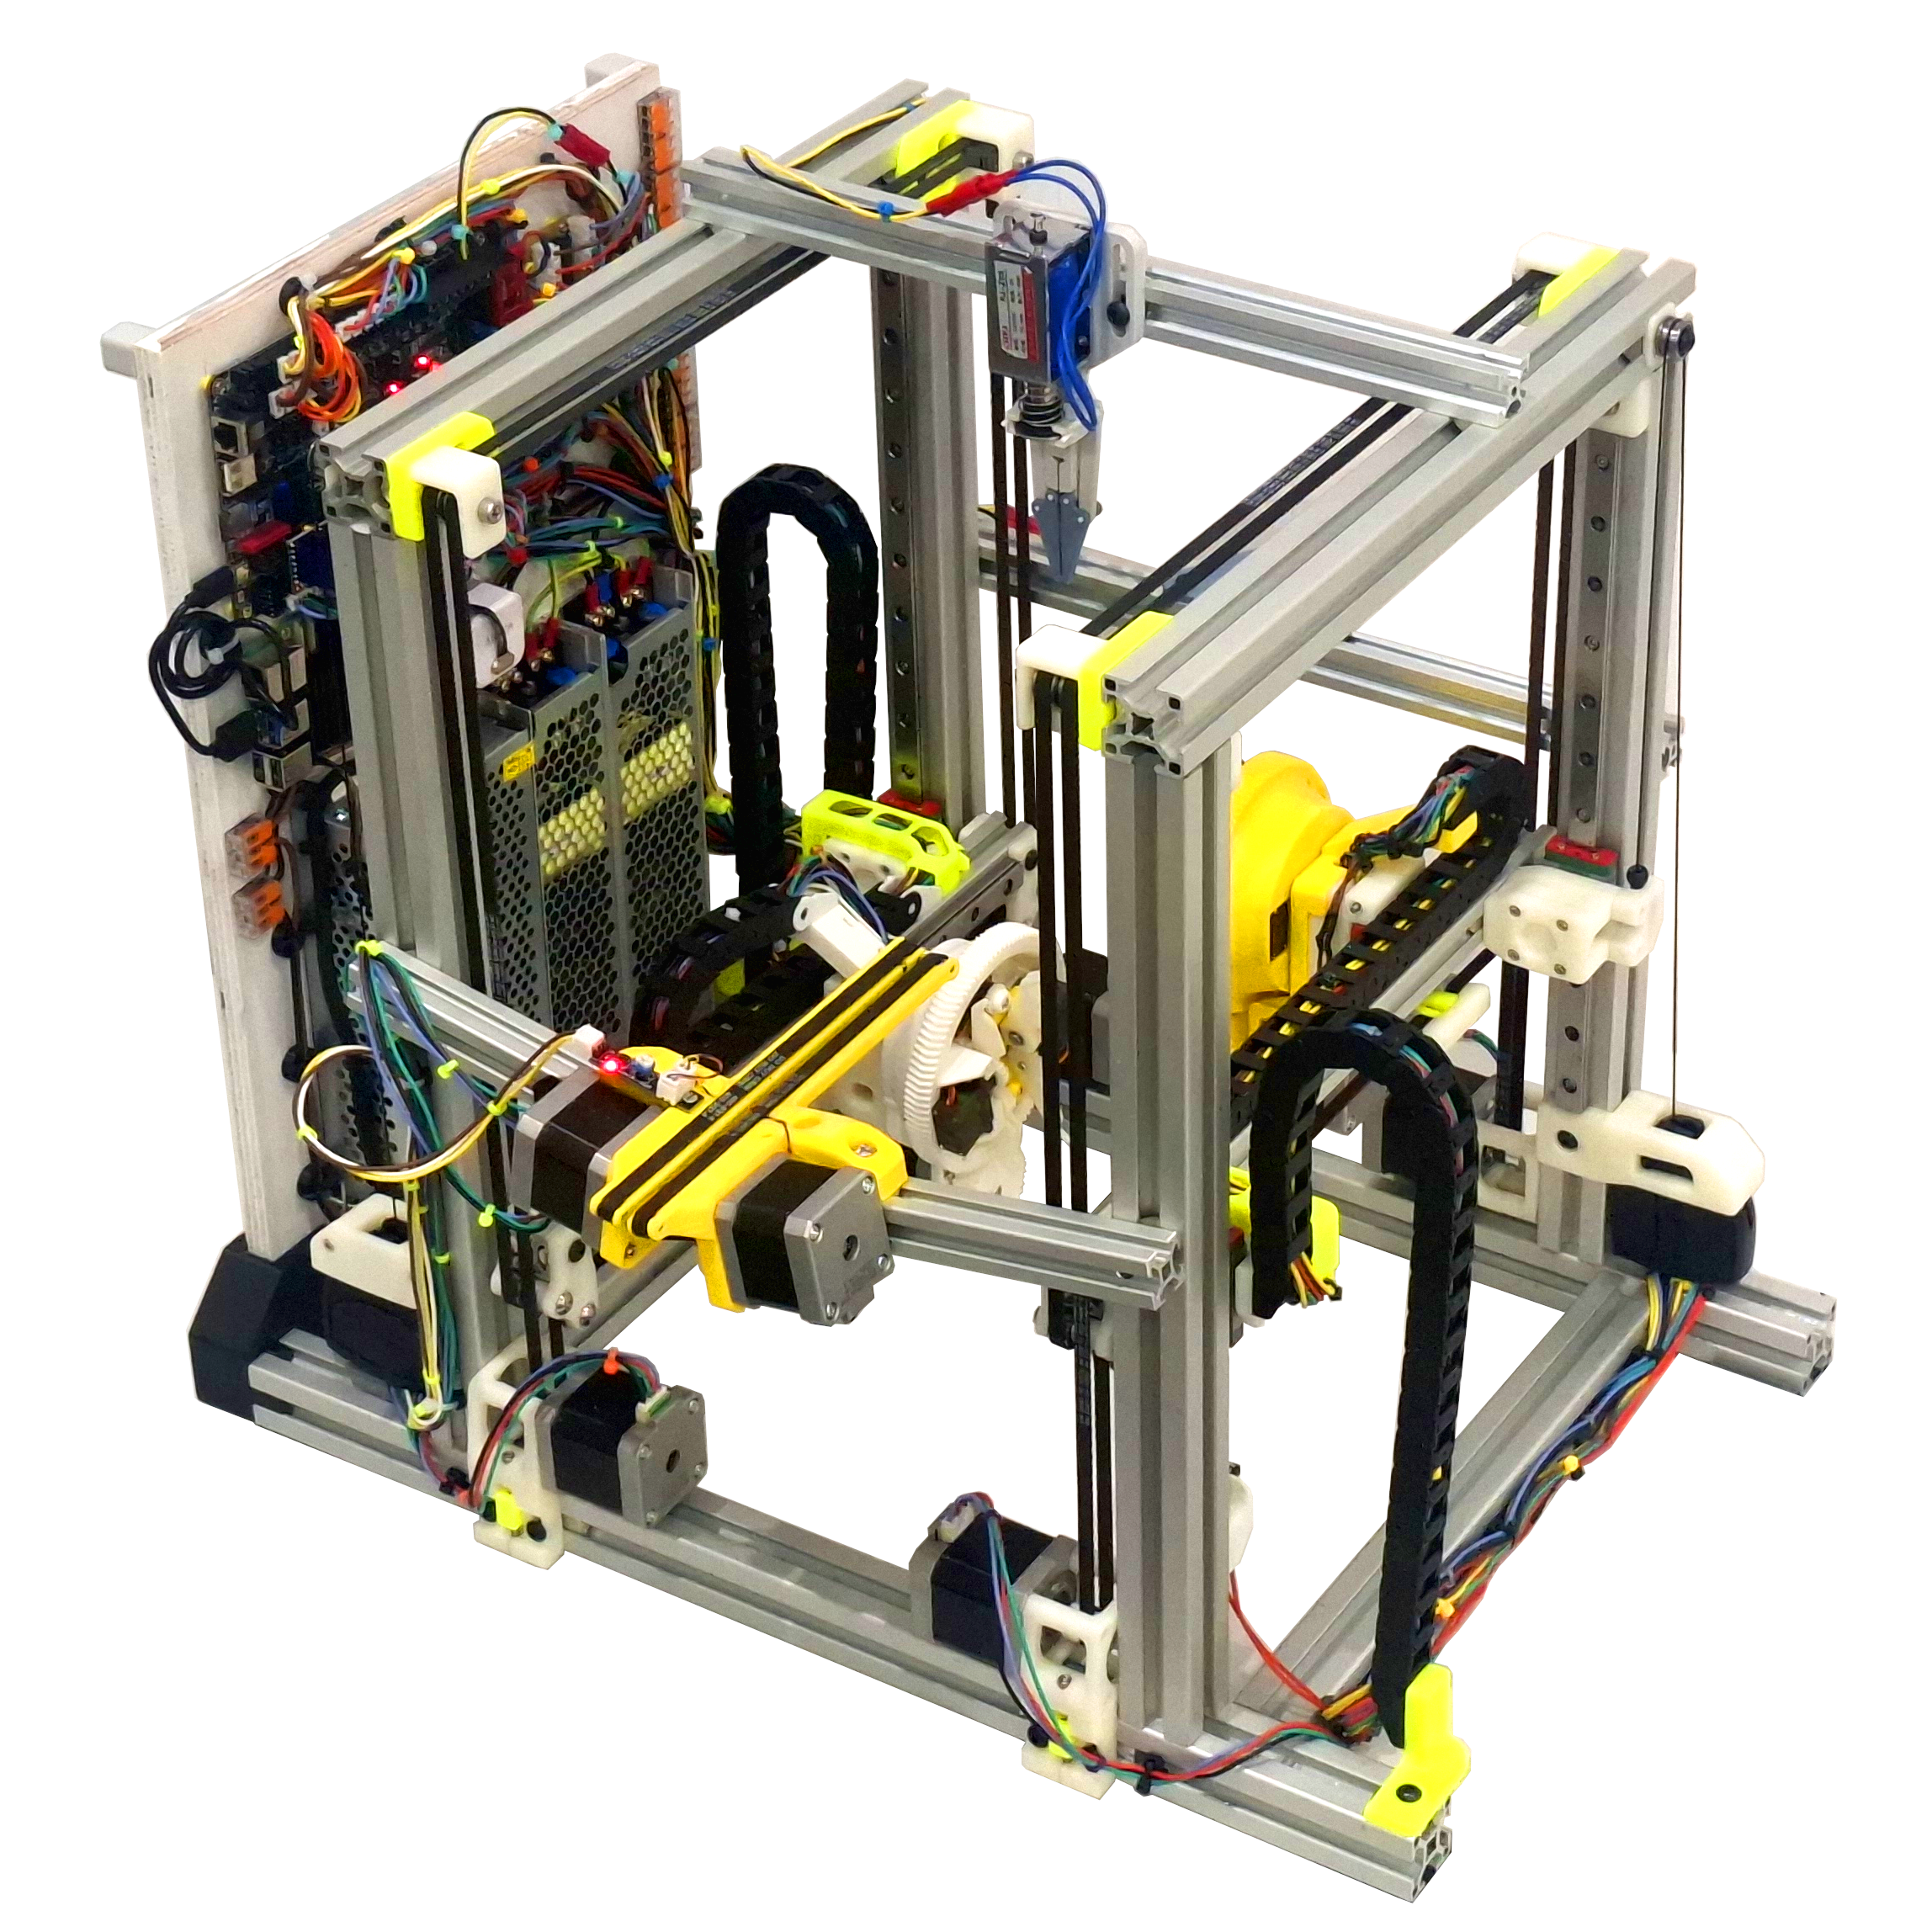
[Jude] says that daisy stem shape and diameter have the most impact on reliability, so it’s very important to constrain the daisies such that the scalpel and threading operations work reliably. This is primarily done with v-shaped profiles in the grippers which automatically center stems of different sizes. The sheath around the scalpel blade also plays a role in constraining and supporting the stems as they are gently pierced and sliced. Tuning these elements was a big part of making the system work.
Watch it in action in the video (embedded below) which shows how clever mechanical design can turn an uncertain problem — like how to handle daisies of different sizes — into a deterministic one with the help of clever mechanical design. That same concept is at work in everything from simple nut sorters to highly complex paper airplane machines.

You must be logged in to post a comment Login